Group
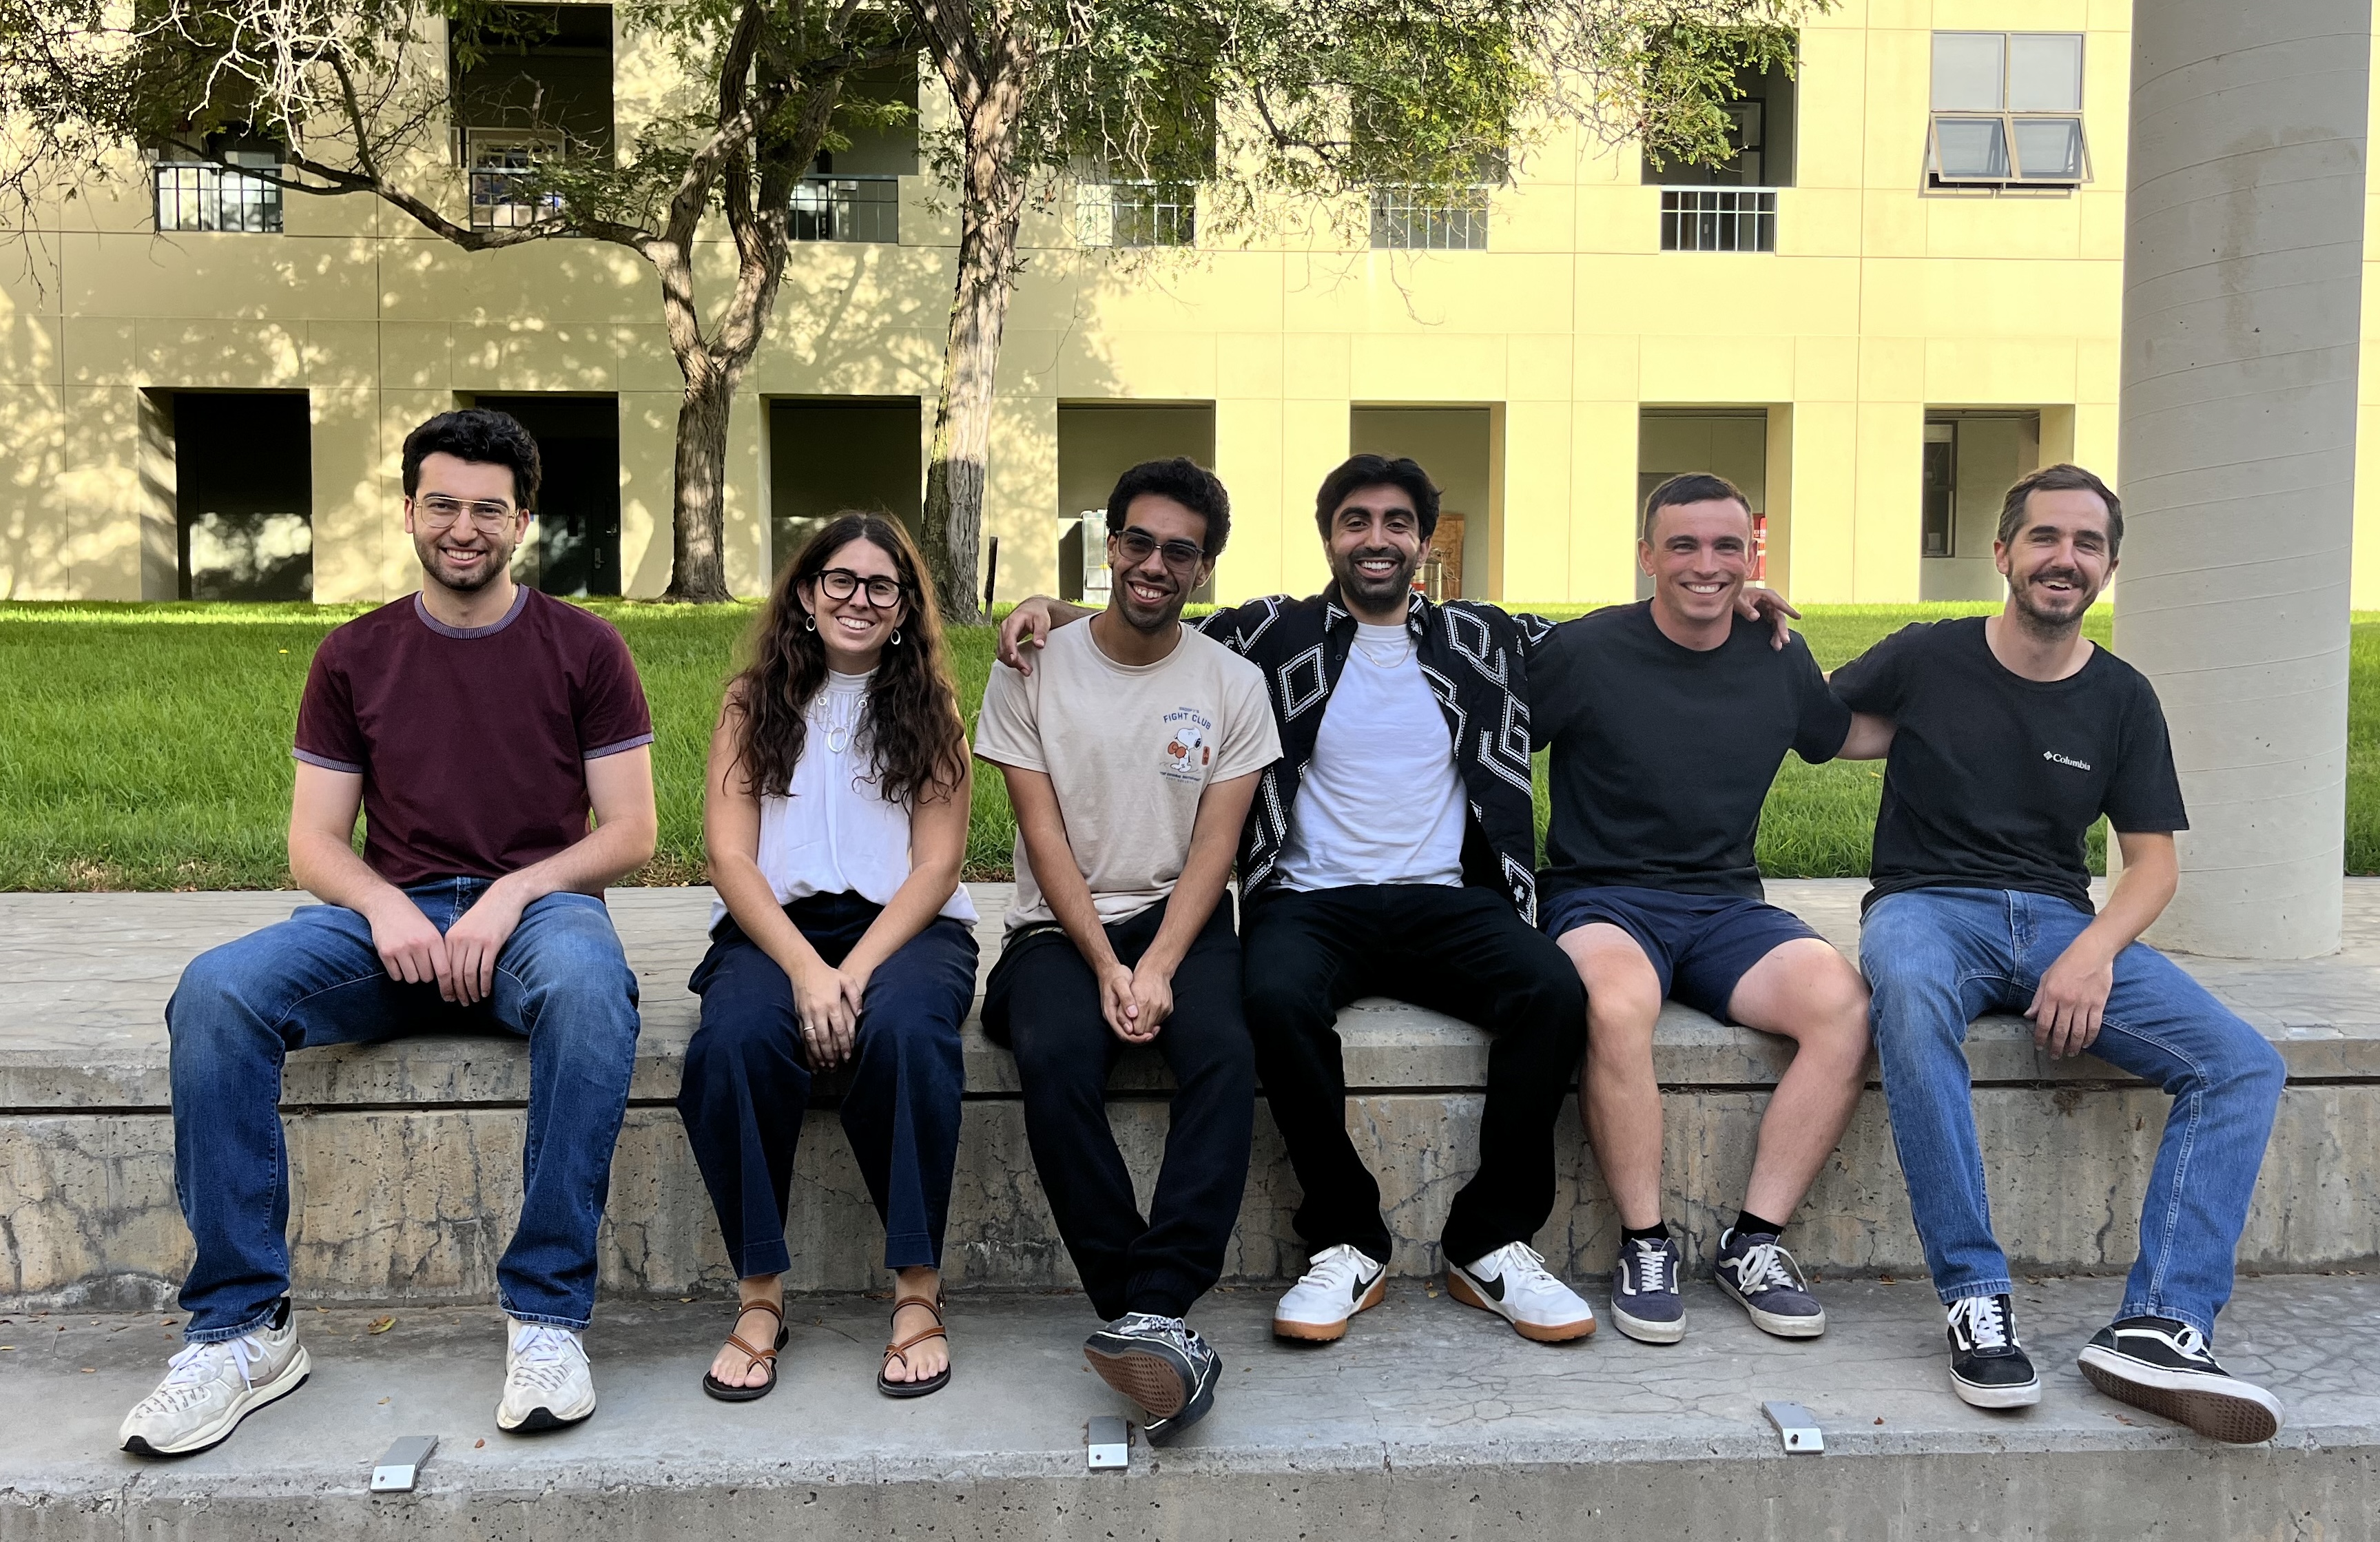
The Robot Optimization and Learning Lab (ROLL) develops the mathematical foundations of high-performance robot planning, control, and learning.
Graduate students
- Andres Torres (co-advised with Elliot Hawkes)
- Cayetana Salinas Rodríguez (co-advised with Jason Marden)
- John-Paolo Casasanta
- Jonathan Lane
- Yufeiyang Gao (co-advised with James Preiss)